Featured Post

Beolover SyncDrive: DC Platter Motor Replacement for Beogram 4002 and 4004 (Type 551x and 552x)

Late Beogram 4002 and the 4004 (Types 551x and 552x), which have DC platter motors instead of the earlier synchronous AC motors usually suff...

Showing posts with label deviation. Show all posts

Thursday, May 25, 2017

Beogram 4004 (5526): Restoration of the DC Platter Motor and RPM Stability Test

After replacing the RPM trimmers, the RPM relay and the light bulbs in the RPM trimmer panel with LEDs, it was finally time to restore the DC platter motor of this Beogram 4004 (5526). This sequence is important, since one can only test the RPM stability performance of the motor properly after the entire RPM control circuit has been rebuilt. This shows the extracted motor:
The motor needs to be completely disassembled to get to the dried out Oilite bearings:
The bearings are the two small donuts on the black pad. I infused them with motor oil under vacuum:
The raising bubbles indicate that air is drawn from the porous brass bearing material. This creates space for oil to enter the bearing. After about 12-24 hours the process usually stops, at which point the bearings are again full of oil.
This shows the bearings after the infusion process:
After reassembling the motor I put it back into the deck and adjusted the RPM with the BeoloverRPM device:
Then I used the device to measure a RPM stability curve over 18 hours:
This motor showed an exceptionally stable RPM performance and can be considered ready for duty.


Monday, April 25, 2016

Beogram 4002 (5514): RPM Performance Measurement after Restoration of DC Motor and Control System

After rebuilding the DC motor and the control system of the Beogram 4002 (5514) that I am restoring right now, it was time to do a RPM performance test. I set up my BeoloverRPM device that allows the long-term logging of the platter RPM, and then did a 24 hrs test:

After the data was logged on my computer, I graphed it relative to a measurement that I took when I initially received the unit for restoration. This shows the two curves in comparison:
The red curve shows the performance before the restoration. The typical telltale sudden negative RPM spikes are visible that indicate failing brass sleeve bearings in the DC motor. This is very common for DC motor Beograms. In this case the spikes are still fairly moderate, but would have been audible since they are in the 1% range. The black curve shows the performance after rebuilding the motor and the installation of new RPM trimmers and RPM relay. The large spikes are gone and the variations are much smaller. There are still some variations, which are related to the intrinsically slightly erratic performance of the analog motor control system, which is affected by temperature changes and probably the moon phase (that was a joke...;-). Some Beograms show them others do not. At this point I do not have an answer why they sometimes occur. The good news is that they are fairly slow over time and also small enough that one cannot hear them. The short term 'wow and flutter' RPM changes (the high frequency 'noise' on these curves) are within the spec given in the service manual (0.05%).  So this Beogram is back in business.

Sunday, February 7, 2016

Beogram 4002 (5513): More RPM Measurements

This is a follow up on yesterday's post about this Beogram 4002 (5513). I did an overnight RPM performance measurement with my BeoloverRPM device. This is the curve that I measured:
This result is pretty much as good as it gets for the DC motor versions. Minimal <0.05% variations over time satisfying the specifications stated in the service manual. The initial slope during the first couple hours is usually observed in the 551x and 552x models. I currently think it is a result of D13 (the Zener diode that stabilizes the DC motor supply) and R12 with which it forms a pretty stiff (i.e. high current) voltage divider to set the base voltage of TR2 heating up. After a while the temperature stabilizes at a certain value in equilibrium with the environment. The band gap change in the semiconductor of the Zener changes its Zener voltage and with that the motor slowly gets a bit more power until a sable condition is achieved. This 'ancient' voltage regulator design is a bit of a drawback of the DC motor versions of the 4002. But one should not get to worked up about it since the change is pretty slow, and only represents a total ~0.3% change, hardly noticeable by most listeners. I am thinking this phenomenon could possibly be alleviated via the adaption of the circuit to use a modern voltage regulator. 

Beogram 4002 (5513): Initial RPM Performance Characterization

This is a follow up to my initial post about this Beogram 4002 (5513). In the meantime I did a RPM performance evaluation of the unit using my recently developed BeoloverRPM device.

This measurement clearly demonstrated the suspected sudden speed variations. This graph shows the RPM vs. time over an approximate 24 hrs period:
The sudden negative spikes suggest that the DC motor control system and the motor itself needs an overhaul.


Wednesday, January 20, 2016

Beogram 4002 (5513): RPM Stability Test and an Updated Display on the BeoloverRPM Device

I spent some time learning to program the small display that I integrated into my BeoloverRPM device that is useful for precision RPM adjustment as well as long term RPM stability characterization. I added min and max values as well as the total measurement time. Here is an impression of the display:


Quite high res and a nice contrast! However, guys of my age at least will need reading glasses to appreciate the small font...;-). Is life ever perfect??. 
Anyway, I applied this new BeoloverRPM version to the Beogram 4002 that I just got going again and I performed a 12 hour RPM measurement. Here is the resulting graph:

This is a pretty good result about matching the specified 0.05% fluctuation number of the service manual. There are four spikes that exceed this specification (they are about 0.15% deviations). I have now measured a few 4002s with DC motor, and they all seem to have these spikes once in a while if one waits long enough. I think we see here the shortcomings of purely analog feedback systems. While these spikes are clearly measurable, they will be hardly audible. Most people can only detect changes of about 0.3 to 0.7%. So this Beogram should be fine for enjoying music.

Saturday, January 16, 2016

BeoloverRPM: Now with Display!

This is an update to my earlier post about my BeoloverRPM device. It allows the measurement of RPM performance of Beogram 400x models over time. It is also very useful for precise RPM calibration. I now tested the original version on a few Beograms and I felt a display would make it much more pleasant to use for simple RPM adjustments in addition to the RPM vs. time serial port printout. Tonight, I finally figured out how to program a small display that I integrated into a modified enclosure of the unit. Here is an impression of the current setup:


Right now it just shows the actual RPM...I will fancify this readout a bit more and then this should be ready for primetime.

Wednesday, December 23, 2015

BeoloverRPM: The Shop Version

This is a follow up to my initial post about my BeoloverRPM device that can be used to quantify RPM stability and fluctuations in Beogram 400x and 8000x models (essentially all models that have 24 radial rubber strips on the platter).

I realized that a main application of the BeoloverRPM device is precision adjustment of the RPM in the analog 400x models. With a currently estimated precision of better than 0.03% the Beolover RPM device substantially outperforms the standard calibration discs that use the grid frequency from a light bulb, and also the 'AC motor Beogram way' of adjusting the motor frequency with an oscilloscope. Both of these 'traditional' methods yield maybe a precision of 1%. Similar errors arise when using a test record and a 3.3kHz or 1kHz tone...oscilloscopes are just not that great when it comes to measuring frequency precisely. A better way is to use a spectrum analyzer with a test record, but even this is fraught with significant errors due to non-centered records and noise issues. 

In difference to these analog methods the BeoloverRPM device precisely measures the time that it takes for the black ribs to pass by the optical sensor, and microcontrollers are very good at measuring time precisely due to their quartz oscillators and their ability to do things very quickly. In fact it mimics the way the 800x models measure the RPM for their feedback control mechanism. And they are very precise at keeping 33.33 RPM over a long period of time. The BeoloverRPM is based on processor interrupts generated by the optical sensor, which essentially means that the error of the measurement comes mainly from the optical performance of the sensor. This remaining error is dealt with by doing a statistical real-time analysis of the measured data. The generated standard deviation output allows monitoring the quality of the measurement and/or the performance of the motor.

Using the BeoloverRPM device for RPM adjustment requires that it can be securely mounted on a Beogram while it is in service position so one can access the base RPM trimmers for the base RPM adjustment. This meant I had to come up with a different design of the system. I realized that it is best to clamp it directly on the metal frame of the enclosure. This allows to be close to the platter while giving a high mechanical stability to ensure a stable sensor position relative to the platter (correct distance is very important for the accuracy of the sensor).

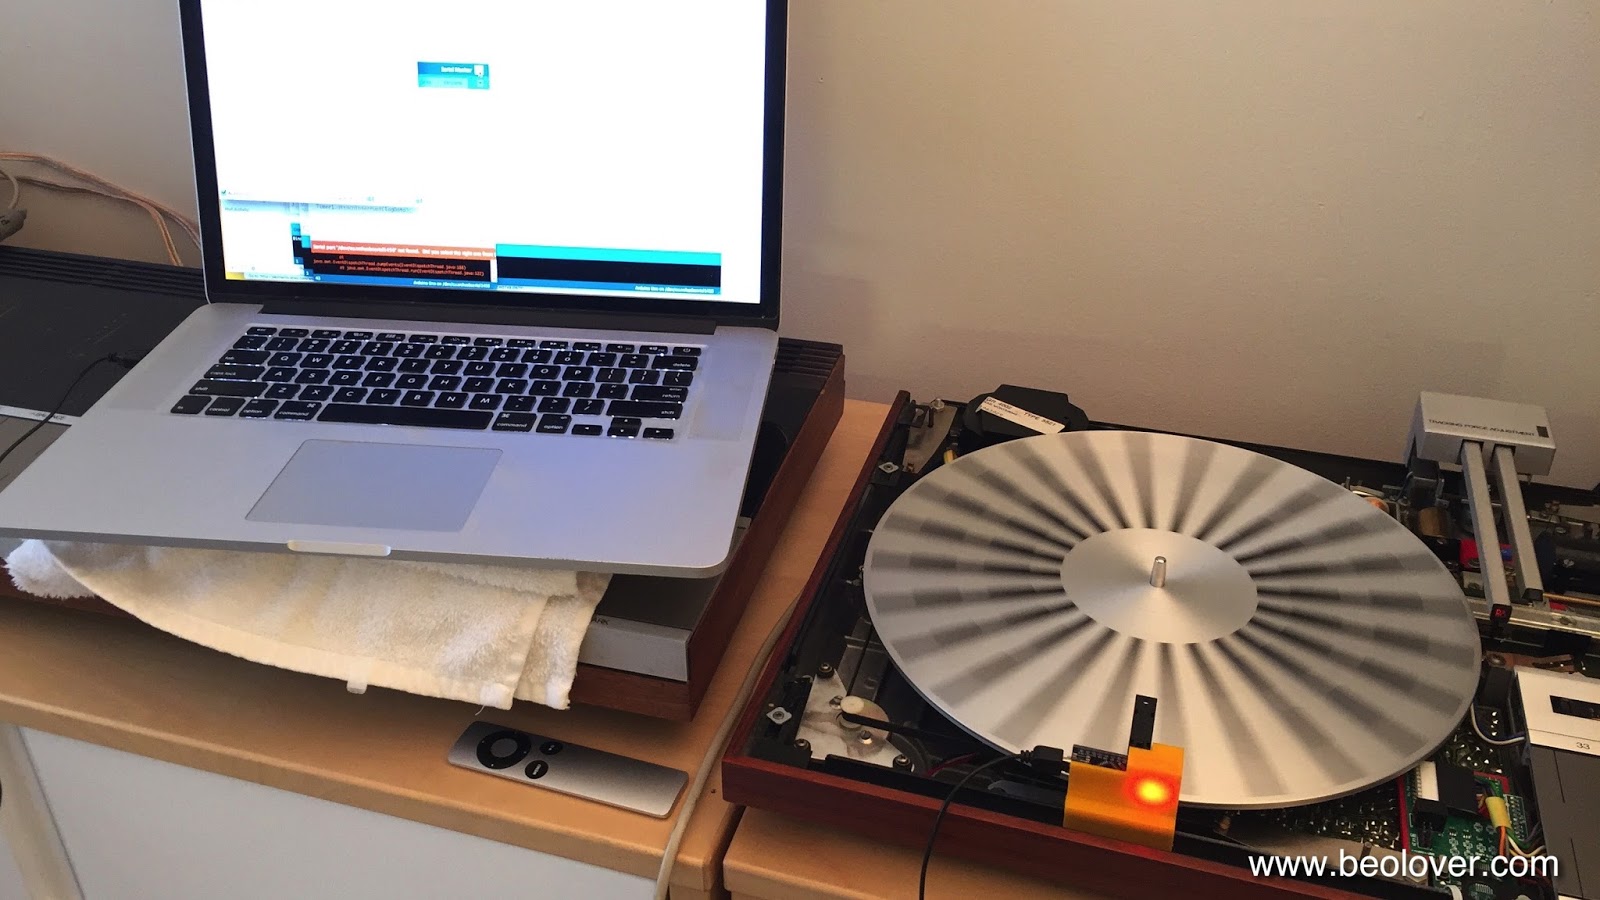
Here are a few impressions of the current state of affairs. This shows the system in action:

Doesn't the power LED look pretty as it shines through he orange plastic print??...;-) The device hooks up to a laptop via a standard mini-USB flex cable. It simply bangs its data through the serial port in ASCII, which allows to use any terminal software on the computer to do the readout. I use the Arduino IDE's serial monitor. The device is now based on an Arduino Nano board with a CH340 USB interface. This makes it necessary to install the appropriate USB driver for this chip. Other than that it is 'plug and play'. The main advantage of this re-design, however, is that there is no more cable between microcontroller and sensor. This makes it much more straight forward with regard to assembly and use stability.

Here are a few detail shots. This shows the final design in front of the preliminary design studies of the plastic cradle (it is notoriously difficult to make a 3D print of a small part to fit something else precisely, and usually only extensive trial and error results in a satisfying fit):

I designed a spring clamp at the bottom for sticking it on the Beogram frame since the 4000 has a thinner frame than the later 4002/4 models. That way the cradle fits on both types:

The small slot is for pushing out the circuit board in case one needs to extract it. It makes a pretty solid press-fit with the cradle. Here is a detail photo how it clamps onto the Beogram frame:

A very solid fit for a precision RPM measurement! I want my customers' vinyls to play at the correct pitch! I am thinking about a 'consumer version' based on my initial design, which could have a direct LCD (or even a 'B&O style red LED 7-segment 4 digit back to the 1984 future style'...;-) display readout, so one could do a RPM check once in a while (yes, there is indeed some drift over time and depending on temperature in these classic analog designs) and compensate with the user accessible RPM trimmers on the control panel for continued precision listening enjoyment. This is Beolove!


Thursday, December 17, 2015

BeoloverRPM: Beogram RPM Calibration Device

Sadly, the Beogram 4002 that I restored a little while ago did not pass muster. It had initially come  to me with an indication of sudden and gradual RPM fluctuations and I thought I had fixed the issue by replacing the RPM relay and the trimmers as well as the DC motor, which showed a strange feedback signal whenever the fluctuations occurred. But not so. While the phenomena were somewhat alleviated, some spontaneous variation still occurs occasionally. Per my customers description it happens maybe once per LP, i.e. it needs to be treated as an intermittent issue. Which are notoriously difficult to fix. 
I decided I needed to be able to measure and quantify the issue before I would be able to attempt another stab at fixing it. The Beolover never gives up, but this one is a tricky one. The last few days I worked on designing the "BeoloverRPM" device, which now allows me to quantify and monitor the RPM of a Beogram with fairly high precision (I think it maybe about 0.03%) over time. I also implemented an automatic fluctuation detection mechanism based on monitoring the standard deviation of the measurement. 

I designed a sensor head, which uses the black ribs found in the Beogram 400x and 800x models to detect the RPM of the platter. Here are a few impressions. The front is curved to fit the platter circumference, and the reflective optosensor unit extends via a fork over the platter

I implanted two M8 bolts into the back of the unit to give it some more weight so it would sit securely next to the platter:

Here is is shown in action measuring the platter of the Beogram 4000 that I just finished up:

It appears to be floating due to rubber feet inserted into the bottom of the body (I was inspired here by the Beogram 8000's rubber bumpers that dampen the impact of its hood when it closes)
The most crucial design parameter was the distance between sensor and measured features. Its optics are fixed, and I determined the best measurement resolution results at a distance of 9 mm. I printed several versions of the housing until I got that distance about right.

Once I had the sensor and verified that I could use it for RPM measurements I sat down and programmed an Atmega328p (aka Arduino) to measure the RPM and do some statistical evaluations. At this point the firmware is able to log the RPM and the standard deviation in timed intervals (10s in the example below). It also detects sudden deviations through monitoring the difference between the running mean of the standard deviation and the current standard deviation. This difference is quite sensitive and a proper threshold allows to hone in on a certain level of fluctuation.

Here is an impression of the printout that is generated:

The ***-marked % deviations were the result of slightly touching the platter with my finger a couple of times. It is interesting to note that the RPM shows as ~33.71 even though I calibrated the RPM of the Beogram 4000 using the AC motor frequency as specified in the Service Manual. It is obvious that this calibration is about 1% off. Naturally I wondered if a measurement error would be responsible for the discrepancy, but a test of the BeoloverRPM device on my Beogram 8000 revealed a proper measurement of 33.32 RPM, which is very close and possibly even at least partly a result of the Beogram 8000 being slightly off (the Service Manual specifies a 0.02% RPM accuracy).
As a next step I will implement an external trigger function for my oscilloscope that I can measure the vitals of a turntable at the moment a fluctuation occurs. Hopefully, this will allow me to figure out what the issue is with the fluctuating 4002! This is Beolove!