Featured Post

Beolover SyncDrive: DC Platter Motor Replacement for Beogram 4002 and 4004 (Type 551x and 552x)

Late Beogram 4002 and the 4004 (Types 551x and 552x), which have DC platter motors instead of the earlier synchronous AC motors usually suff...

Thursday, October 8, 2015

Beogram 8000: Not Responding to Keyboard Input - Not Working Rotary Encoder Feedback

A Beogram 8000 hailed from Tokyo in search for some TLC. It was initially purchased from ebay and supposed to be in excellent condition. Once unboxed, however, it turned out that the unit did not work properly. There is already an extensive thread on Beoworld.org about the issues this unit displayed. In a nutshell, when pressing start the arm would run to the end of its range and then be stuck.
Yesterday, I opened the unit up and had a look. I immediately suspected a fault with the rotary encoder that is fitted to the spindle that drives the carriage with the arms. In difference to the earlier 400x models, the 800x employ a more modern positioning concept that is based on detecting the angular motion of the spindle and calculating the carriage position from that. This is a concept that is used in most modern control systems involving motors. The encoder unit is very similar to the ones used in the Beomaster 8000 for the volume and FM frequency wheels.
In the Beogram 8000 the evaluation of the encoder signals is done by the microcontroller, which has two inputs that detect the intensity fluctuations on two sensors. The fluctuations are generated via an aperture wheel that sits between the detectors and the IR emitter. Depending on the phase of the fluctuations on the two detectors relative to each other the system can detect the direction of the motion. The number of intensity oscillations tell the traveled distance. This way, the microcontroller always knows where the needle is. This 'feedback' is used to determine where to set down the arm, when it is time to lift and return home etc...
Therefore, when there is no feedback, the controller does not know anymore where the arm is. The firmware seems to be programmed with simple if...then conditionals that cause action depending on the position. If the position does not change in the mind of the controller (in the case of a non-working encoder system) the arm simply continues to travel until it hits the mechanical stop at the end.

All this suggested to me that I needed to investigate the encoder system to get to the bottom of the issue at hand. Below is the relevant section of the circuit diagram. Since I had similar problems already a couple times with Beomaster 8000s that I restored, I first checked on the functionality of the light detectors and the IR diode (OPE1). In the Beomasters the diodes had failed.

With the multimeter I determined 1.2V at the anode of the diode and this told me that it most likely was o.k. (they usually die by going OC). Then I measured the resistance on the photoresistors. They both showed about 1k when shining a strong LED light into the assembly and about 20-40k when just room light trickled into the setup. This seemed o.k., too. 

So I hooked up my oscilloscope and measured at the P2/6 and P2/4 whether I got pulses when manually turning the spindle. Of course the deck needs to be in PLAY mode or another on state to have things powered up. I had it in PLAY with the carriage belt removed, so the motor simply ran but the spindle did not move. This measurement yielded pulses for both encoder channels. The next step was checking the outputs of the opamps. And there I found a first clue to the problem: IC2 had no pulses at the output, while IC1 gave me nice 5V square pulses.
So I had a look at the PCB, and there it was:

The input of IC2 was short circuited to GND. In the above photo that is the IC pin that is associated with R5. It connects to the adjacent GND pad on the left via a gigantic solder ball. In fact if you look at the entire area it is apparent that someone with very little practice in electronics messed around and did some 'expert work'. Another great example of a 'perfect condition' or 'fully restored' ebay unit....(I hope this guy will smolder for a long time in Vintage Hifi Purgatory when his time comes).

Grounding the IC2 input of course results in a zero output signal since then there is nothing to amplify, and that explained my measurement. I fired up my Hakko desoldering gun and removed the solder from the pads and then resoldered them:

And this did the trick. The unit is working again. I put on my least favorite record (Sam Rivers) that I use for this type of testing, and pressed PLAY. The arm moved to the lead-in groove and lowered. Cueing worked and STOP. Very good!


Beogram 4002 (5513): Adjusting the Floating Chassis Height

Once the main platter bearing is adjusted in a Beogram 4002 (5513), the floating chassis height needs to be set in a way that the aluminum surface of the platter is flush with the surrounding aluminum panels. This adjustment is done by turning the nuts that define the height of the leaf springs that keep the chassis suspended for vibration insulation. This is best done with a 8 mm hex wrench bit:

Simply turn it CW to lift the chassis or CCW to lower it. This needs to be done repeatedly for all three of the springs until the platter is flush with the aluminum panels all around. I recently made a video that shows this process on a Beogram 4000. The difference here is that the 4002/4004 models do not have a counter nut, i.e.one should put a dab of paint on the nuts to lock them in place once the adjustment is satisfactory. If the platter is not centered in the aluminum panel (do this with the belt in place) then the position of the chassis can be set by bending the threaded rods on which the nuts sit. This is a bit a dicey operation where some relatively brute force needs to be applied with high precision. Nothing for the faint of heart!

This shows the end result. The platter is fully flush and looks just gorgeous!:

Here another angle showing off the lovely restored keypad:

Aren't they beautiful, these babies?? This is Beolove!


Wednesday, October 7, 2015

Beogram 4002 (5513): Restoration of Worn Keypad

I am approaching the detail&beautification stage of the Beogram 4002 (5513) restoration that I am currently doing. This Beogram has (like 90% of them) a worn keypad. The original coating simply is not up to the stresses presented by skin chemistry containing acids and fats. Usually at this age if the deck has seen even only moderate use the pads show ugly finger smudges. I recently had some pads refurbished by a beofriend in Denmark to have them on hand when needed for restorations (I'd be happy to get you in touch if you want to get your keypad rebuilt!)

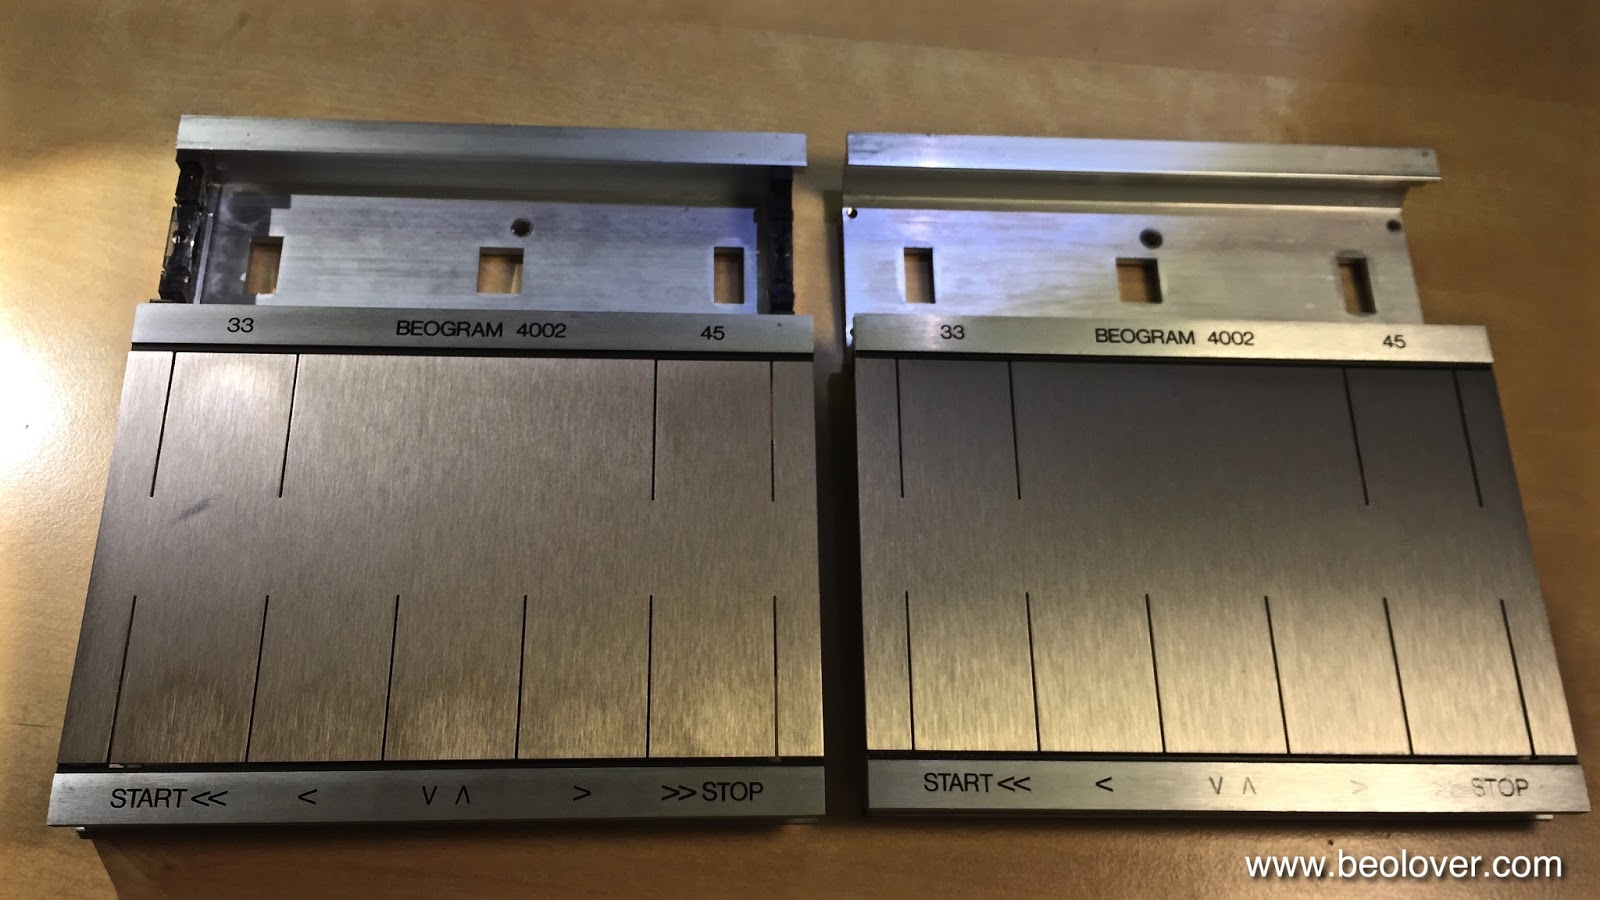
Here are a few impressions. This is the original worn keypad:

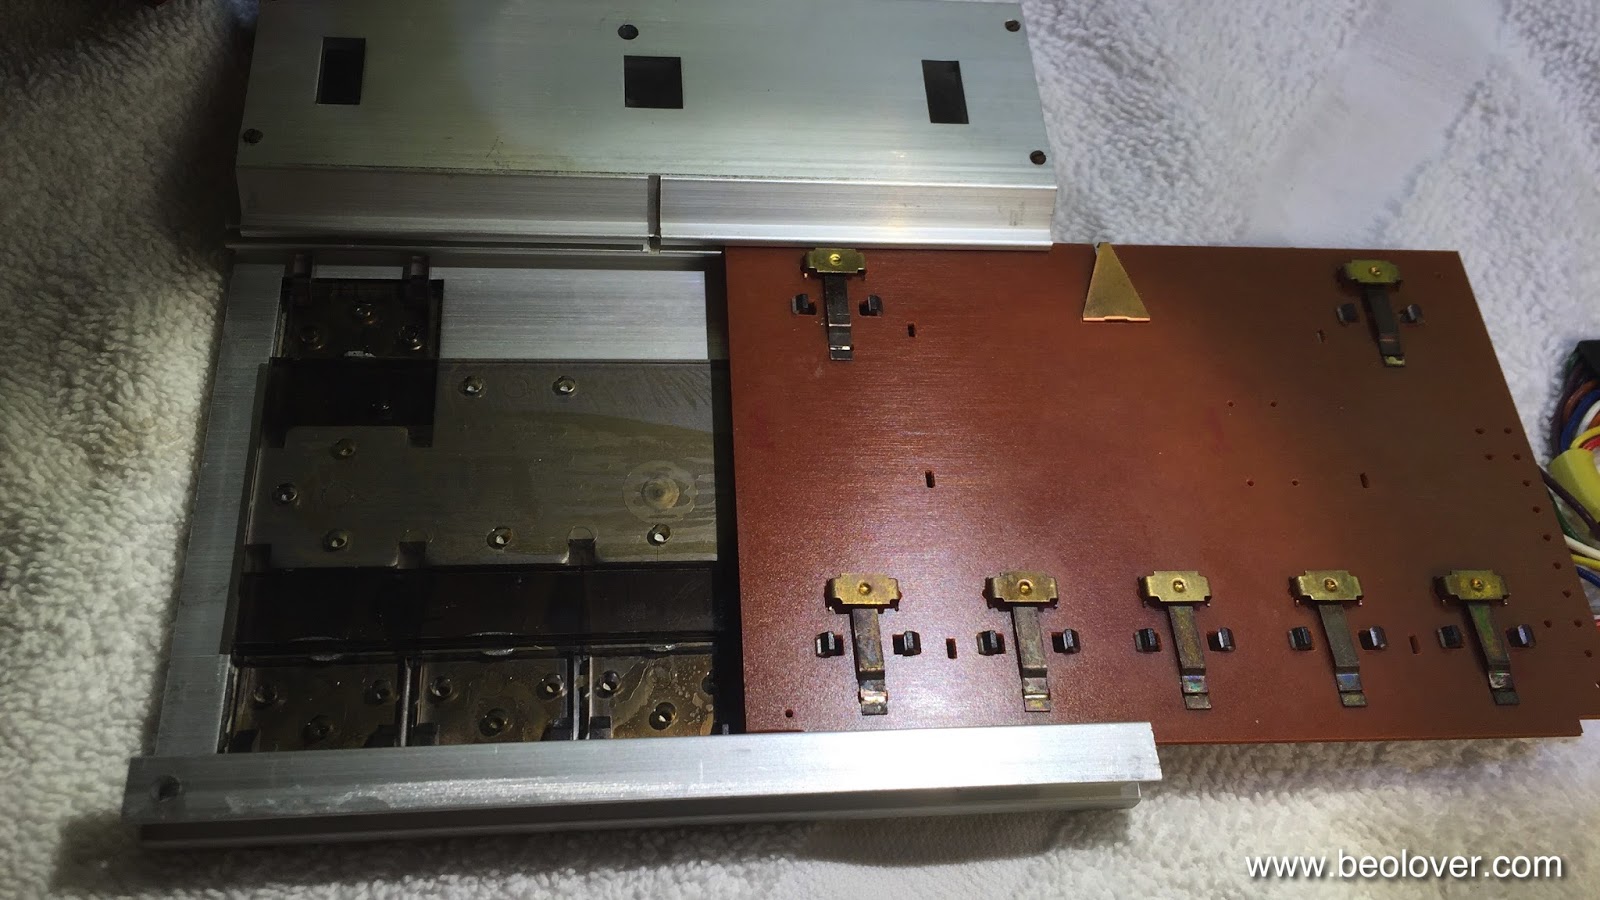
I needed to switch over the PCB that carries the actual switches, hence this was a good moment to refreshen the contact pads. I usually give them a light sanding with 2000 grit paper and then a coat of DeoxIT D100 to prevent further oxidation if they are not bent (if they are one needs to extract them, straighten them out and solder them back into place):

Then it was time to slide the PCB out of the original keypad:

Here is a comparison between old and rebuilt:
And after installation:

Doesn't my friend do an amazing job?? They really look very close to new! Like traveling with a time machine back to a B&O store in the 70s and picking one up!


Tuesday, October 6, 2015

Beogram 4002/4004: Replacement of a Broken Cable Clamp/PCB Holder

The Beogram 4002 (5513) that I am restoring right now had a cracked cable clamp/PCB holder that needed replacement. This gave me a chance to put a part file to work that a Beofriend from New Zealand sent me in exchange for at-cost access to my Shapeway Store parts. I recently had it manufactured at Shapeways since I wanted to test it before adding it to my store inventory. 

Here are a few pictures. This shows the broken clamp:

Here is the replacement part printed in white together with the original broken part:

And this shows it after installation. It makes a nice fit with the PCB and holds it tightly in place while giving the audio cable the support it needs to stay put:

After this successful test, I made the part available to other B&O enthusiasts at my store:


Beogram 4002/4004: Replacement of Decayed Transport Lock Bushings

About 50% of all Beogram 4002/4004s seem to have decayed transport lock bushings. A while back I developed a 3D printed replacement part that can be inserted without needing to disassemble the chassis. The part is available in my Shapeways store. Here is a picture of a set of three bushings (you will need 6 parts. Two make up one complete bushing (See below for a link to the installation video).


The Beogram 4002 (5513) that I am currently restoring also had this problem. When I took it out of the box, the telltale orange fragments were all over the place. So I replaced the fragmented bushings with my 3D printed replacements. Here are a few pictures of this effort taken while I worked on the lock next to the carriage servo motor.
This shows the orange fragments and the lock before I fixed it:

Here you see the remnants of the original lock as it crumbled out of the mounting hole:
After cleaning all the debris, I inserted the lower bushing part:
Then I added the top part:

And then put the lock screw in place together with the mounting plate:

This procedure needs to be done for all three transport locks. When I designed the part, I also made a short video about installing the bushings:

Sunday, October 4, 2015

Beogram 4002 (5513): Lubrication of Platter Motor Bearings

Today I lubricated the bearings of the DC motor of the Beogram 4002 (5513) that I am currently restoring. This shows the motor after extracting it:


This brushed commutator motor has simple sleeve bearings. To get at the bearings, the first step is to take the pulley and the outer housing off. It is a good idea to make marks to remember later in what orientation the bottom plate was mounted to the motor. The pulley is glued to the shaft, i.e. one can simply pull it off. After taking off the two small screws the housing can be opened,

and the motor extracted:

After removal of the black rubber vibration insulation boot the circuit board that connects to the brushes is visible:


After marking the position of the bottom part, the three screws that hold the bottom part can be removed, and the brushes plate pulled off:

This shows the two halves in more detail:


The bottom bearing can be lubricated by putting a dab of silicone grease into the bottom sleeve below the brushes. The top bearing is best lubricated by simply put a bit of grease on the shaft and pushing it up and down through the bearing a few millimeters. After application of the grease, the motor can be reassembled. The commutator is fitted with a slanted plastic disc that pushes the brushes apart and guides them on the commutator while the plate is inserted. This is very convenient and protects the brushes from being bent out of shape. After that simply track back the disassembly steps. Once the motor is back in its outer housing the pulley can be glued back on the shaft with superglue gel. And that is it!


Friday, October 2, 2015

Beogram 4002 (5513): Replacing the Tracking Sensor Light Bulb with a Plug-In Ready SMD LED Assembly

Yesterday, I installed my latest version of the SMD LED light source for the tracking sensor of the Beogram 4002 (5513) that I am currently restoring.

A while ago I developed a drop-in ready SMD LED based assembly for replacing the incandescent bulb fixture. While this worked great, it still required the application of the inconvenient original tracking sensor sensitivity adjustment process. The mechanical positioning of the light sensors relative to the light source is quite tricky, and it is always chore to get this adjustment precisely right. The reason for this is that the mechanism is quite sensitive, while the adjustment mechanism is pretty coarse, requiring a lot of trial and error to get the adjustment right.

A recent beolove-affair with a Beogram 4000 taught me a better way to get this adjustment right: Add a trimmer potentiometer to the LED circuit, which allows the adjustment of the intensity of the LED. This gives an additional adjustment parameter that enables a straight forward fine tuning of the tracking response. I liked this a lot in the 4000, so I adapted the approach to the 4002's higher bulb voltage.

I made a short video about the installation and the tracking response adjustment process for this new design:


Here are a couple high-res pictures of the new LED assembly. I will be happy to provide this part to other enthusiasts!. This shows the added trimmer:

And this is a shot of the bottom side. The LED is in the same spot as the filament of the original light bulb assembly. The body of the replacement part is 3D printed and has the same shape as the lower part of the original fixture. This ensures a precise fit onto the light sensor assembly below the aperture:


This shows the part installed: